

Repository
LiDARCrafter
LiDARCrafter: Dynamic 4D World Modeling from LiDAR Sequences <a href="https://arxiv.org/abs/2508.03692" target='_blank'> <img src="https://img.shields.io/badge/Paper-%F0%9F%93%96-d · License unknown · Maintenance unknown
- License
- Unknown
- :sunglasses: Awesome
- Projects
Specs
- :sunglasses: AwesomeProjects
README
English | 简体中文
LiDARCrafter: Dynamic 4D World Modeling from LiDAR Sequences
Ao Liang Youquan Liu Yu Yang Dongyue Lu Linfeng Li Lingdong Kong Huaici Zhao Wei Tsang Ooi
<p align="center">
<a href="https://arxiv.org/abs/2508.03692" target='_blank'>
<img src="https://img.shields.io/badge/Paper-%F0%9F%93%96-darkred">
</a>
<a href="https://lidarcrafter.github.io/" target='_blank'>
<img src="https://img.shields.io/badge/Project-%F0%9F%94%97-blue">
</a>
<a href="https://huggingface.co/datasets/Pi3DET/data" target='_blank'>
<img src="https://img.shields.io/badge/Dataset-%F0%9F%94%97-green">
</a>
<a href="" target='_blank'>
<img src="https://visitor-badge.laobi.icu/badge?page_id=lidarcrafter.toolkit">
</a>
</p>
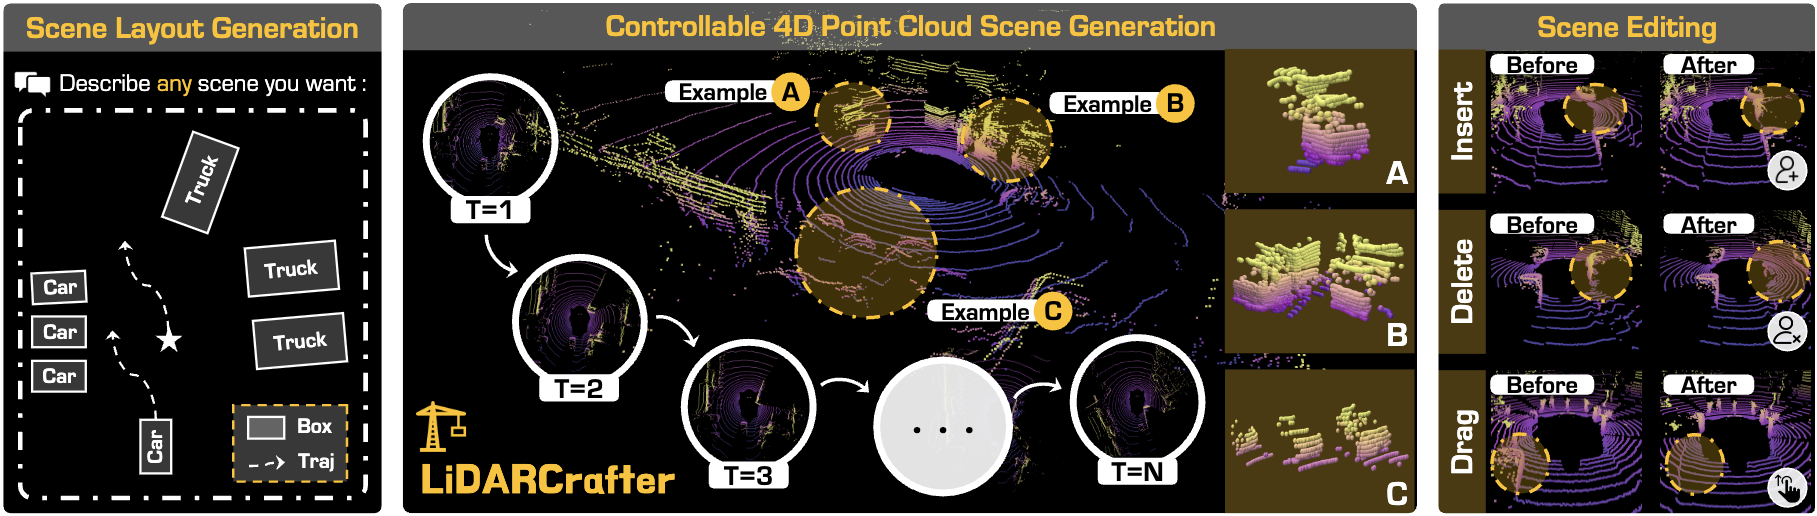
In this work, we introduce LiDARCrafter, a unified framework for 4D LiDAR generation and editing. We contribute:
- The first 4D generative world model dedicated to LiDAR data, with superior controllability and spatiotemporal consistency.
- We introduce a tri-branch 4D layout conditioned pipeline that turns language into an editable 4D layout and uses it to guide temporally stable LiDAR synthesis.
- We propose a comprehensive evaluation suite for LiDAR sequence generation, encompassing scene-level, object-level, and sequence-level metrics.
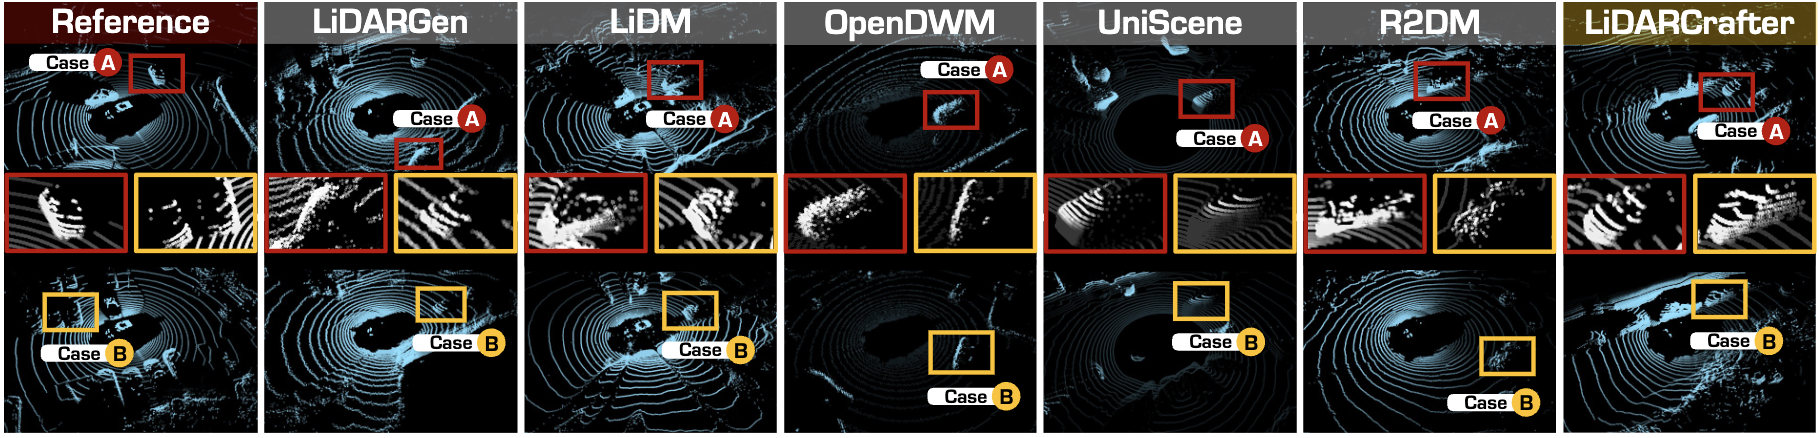
- We demonstrate best single-frame and sequence-level LiDAR point cloud generation performance on nuScenes, with improved foreground quality over existing methods.
:books: Citation
If you find this work helpful for your research, please kindly consider citing our paper:
@inproceedings{liang2026lidarcrafter,
    title     = {{LiDARCrafter}: Dynamic {4D} World Modeling from {LiDAR} Sequences},
    author    = {Ao Liang and Youquan Liu and Yu Yang and Dongyue Lu and Linfeng Li and Lingdong Kong and Huaici Zhao and Wei Tsang Ooi},
    booktitle = {Proceedings of the AAAI Conference on Artificial Intelligence (AAAI)},
    volume    = {40},
    year      = {2026},
}
Updates
- [11.2025] - LiDARCrafter has been accepted to AAAI 2026 for Oral Presentation. :tada:
- [10.2025] - We will soon start organizing the code. All pretrained weights for evaluation can be found at Hugging Face.
- [08.2025] - The technical report of LiDARCrafter is available on arXiv.
Outline
- Updates
- Outline
- :gear: Installation
- :hotsprings: Data Preparation
- :rocket: Getting Started
- :wrench: Generation Framework
- :snake: Model Zoo
- :memo: TODO List
- License
- Acknowledgements
:gear: Installation
Please configure your environment according to the version information in environment.yml.
:hotsprings: Data Preparation
- Create dataset: same as DrivingDiffusion
ln -s ${ROOT_DATA_PATH} ./data/nuscenes
Run bash scripts/create_data.sh for generate:
-
info with track and state
-
Updated pkl with scene graph
-
CLIP feature of scene graph
The file-tree of data is like:
data
├── clips
│   └── nuscenes
│       ├── obj_text_feat.pkl
│       ├── train
│       └── val
├── infos
│   ├── needed_5_framed_token.pkl
│   ├── nuscenes_dbinfos_10sweeps_withvelo.pkl
│   ├── nuscenes_infos_10sweeps_train.pkl
│   ├── nuscenes_infos_10sweeps_val.pkl
│   ├── nuscenes_infos_lidargen_train.pkl
│   ├── nuscenes_infos_lidargen_val.pkl
│   ├── nuscenes_infos_train.pkl
│   ├── nuscenes_infos_val.pkl
│   ├── nuscenes_object_classification_train.pkl
│   └── nuscenes_object_classification_val.pkl
└── nuscenes
:rocket: Getting Started
Evaluation
- Train classification model
python train/train_classification_pointmlp.py
- Train uncertainty model
python train/train_uncertainty_glenet.py
For each generated 1w model
- Extract foreground samples
python evaluation/extract_foreground_samples.py --model ori
:wrench: Generation Framework
Overall Framework
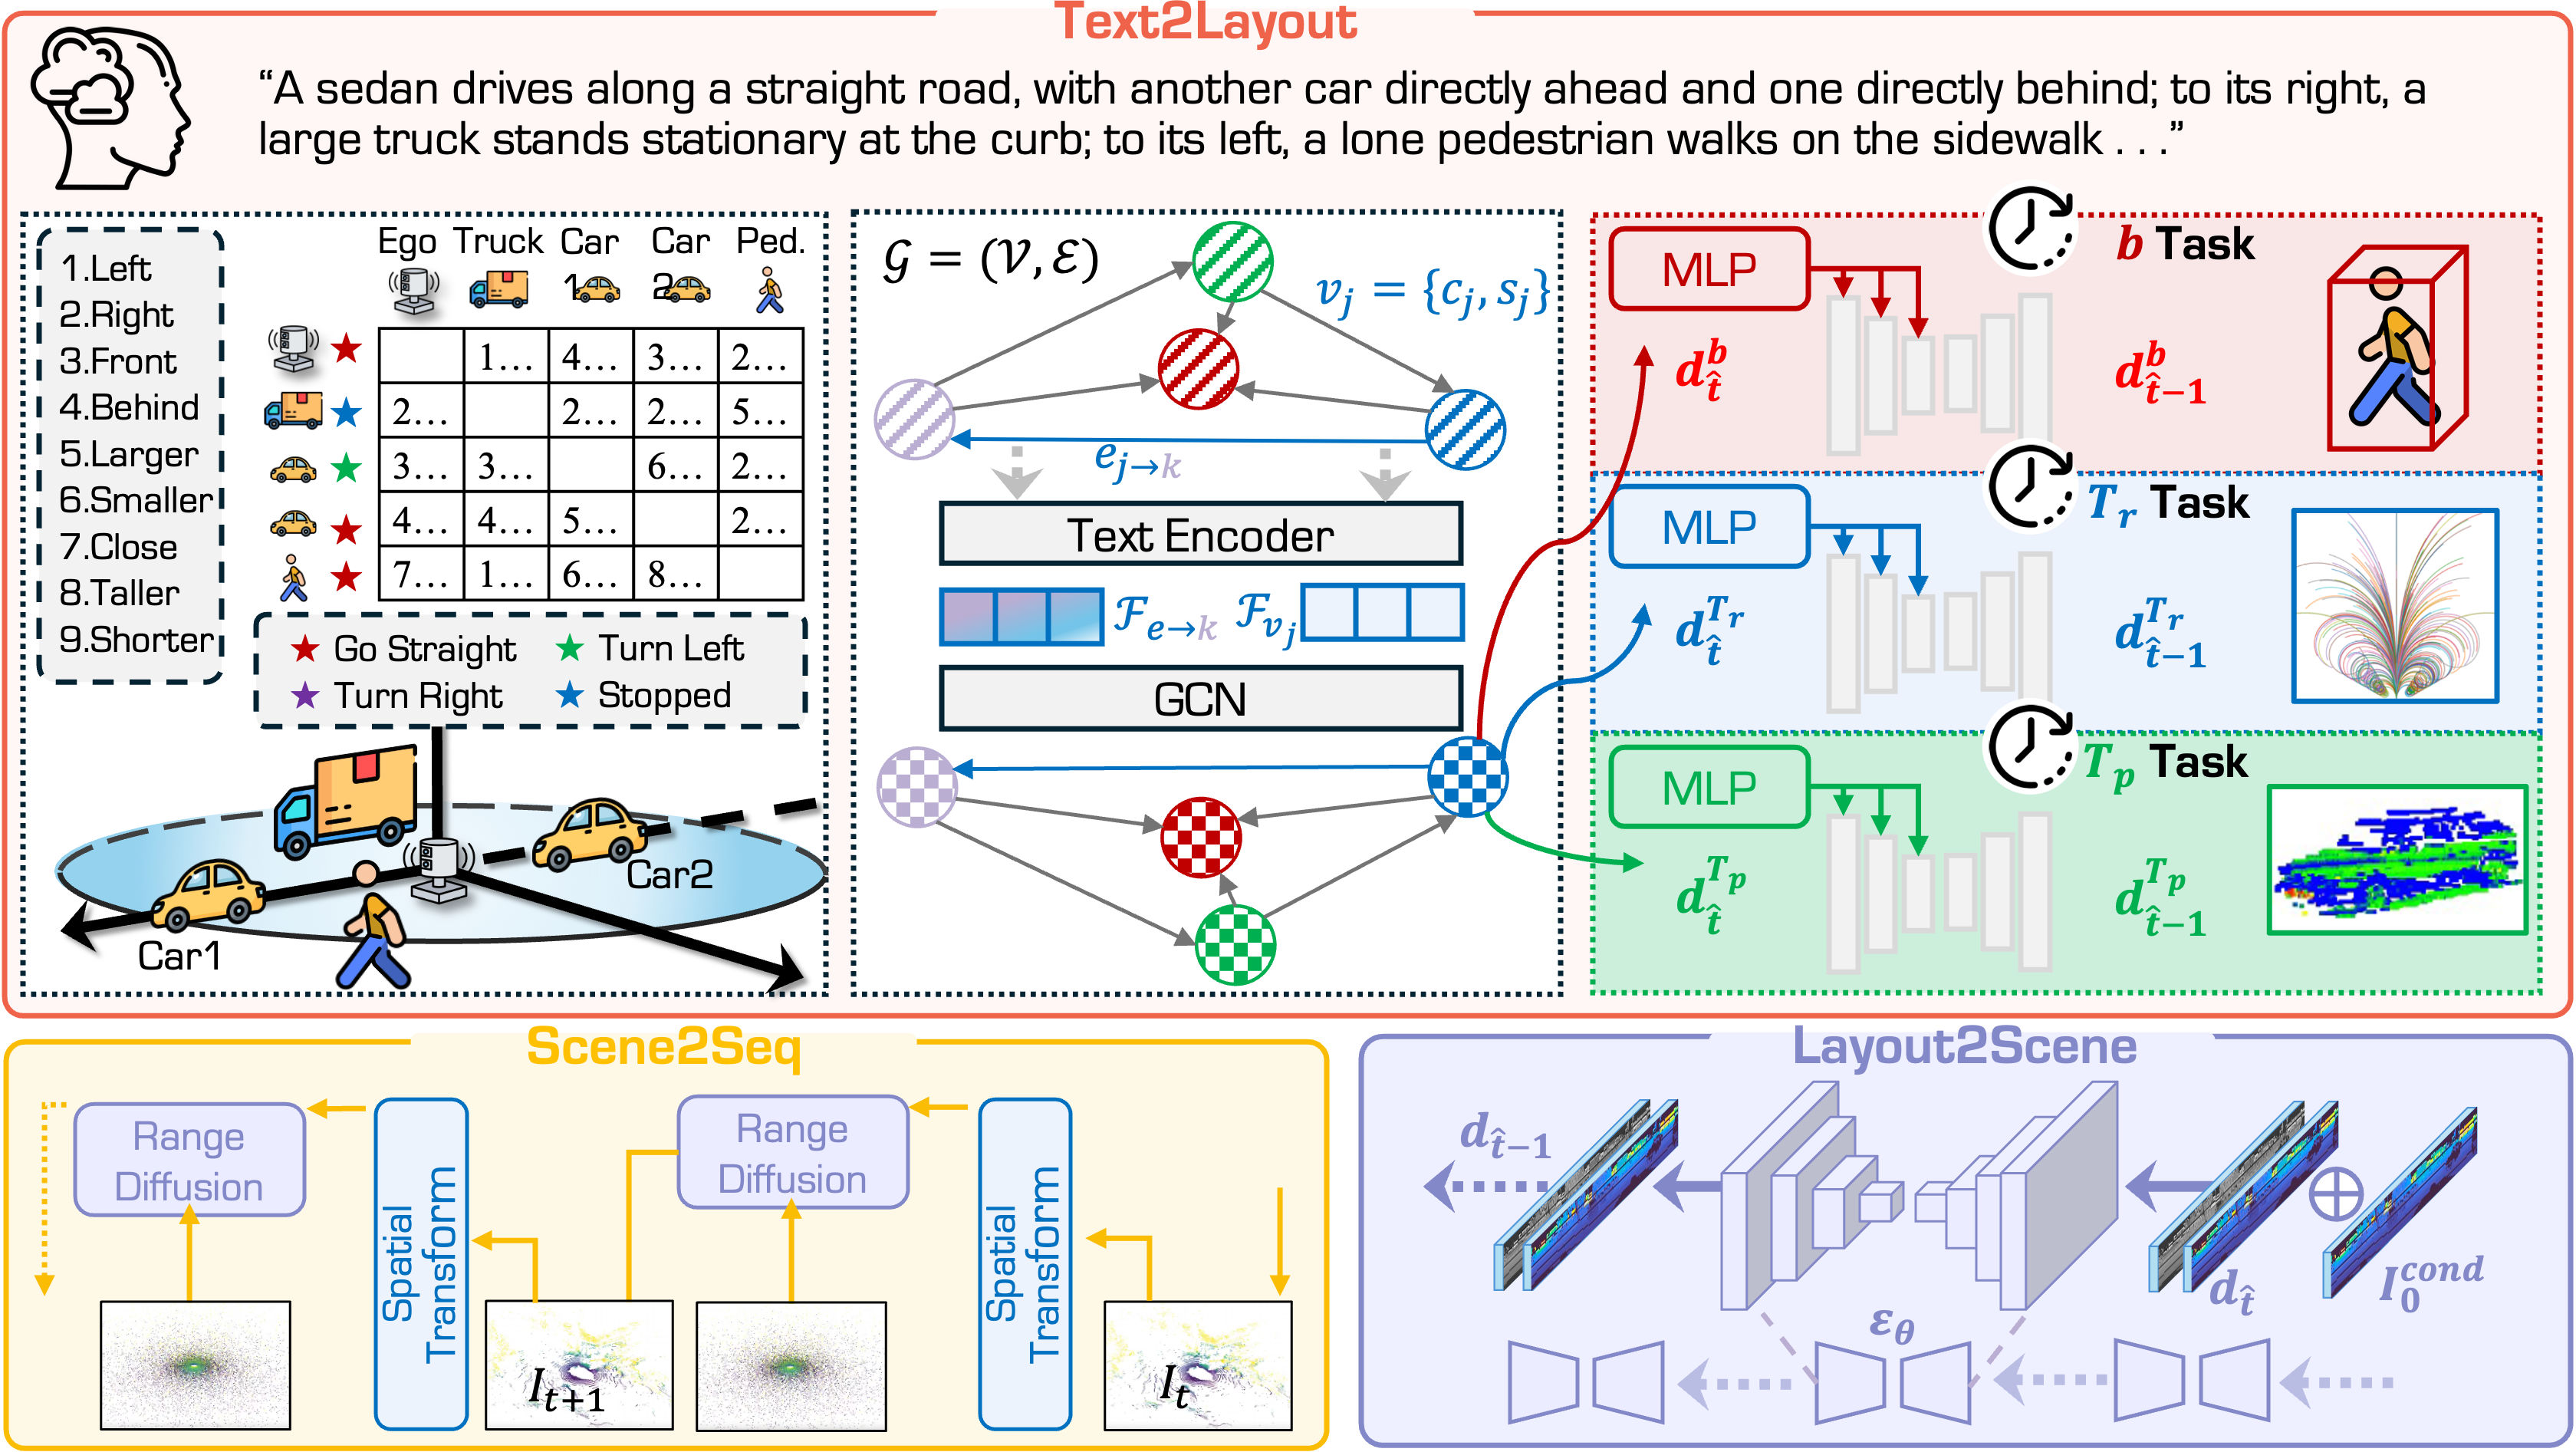
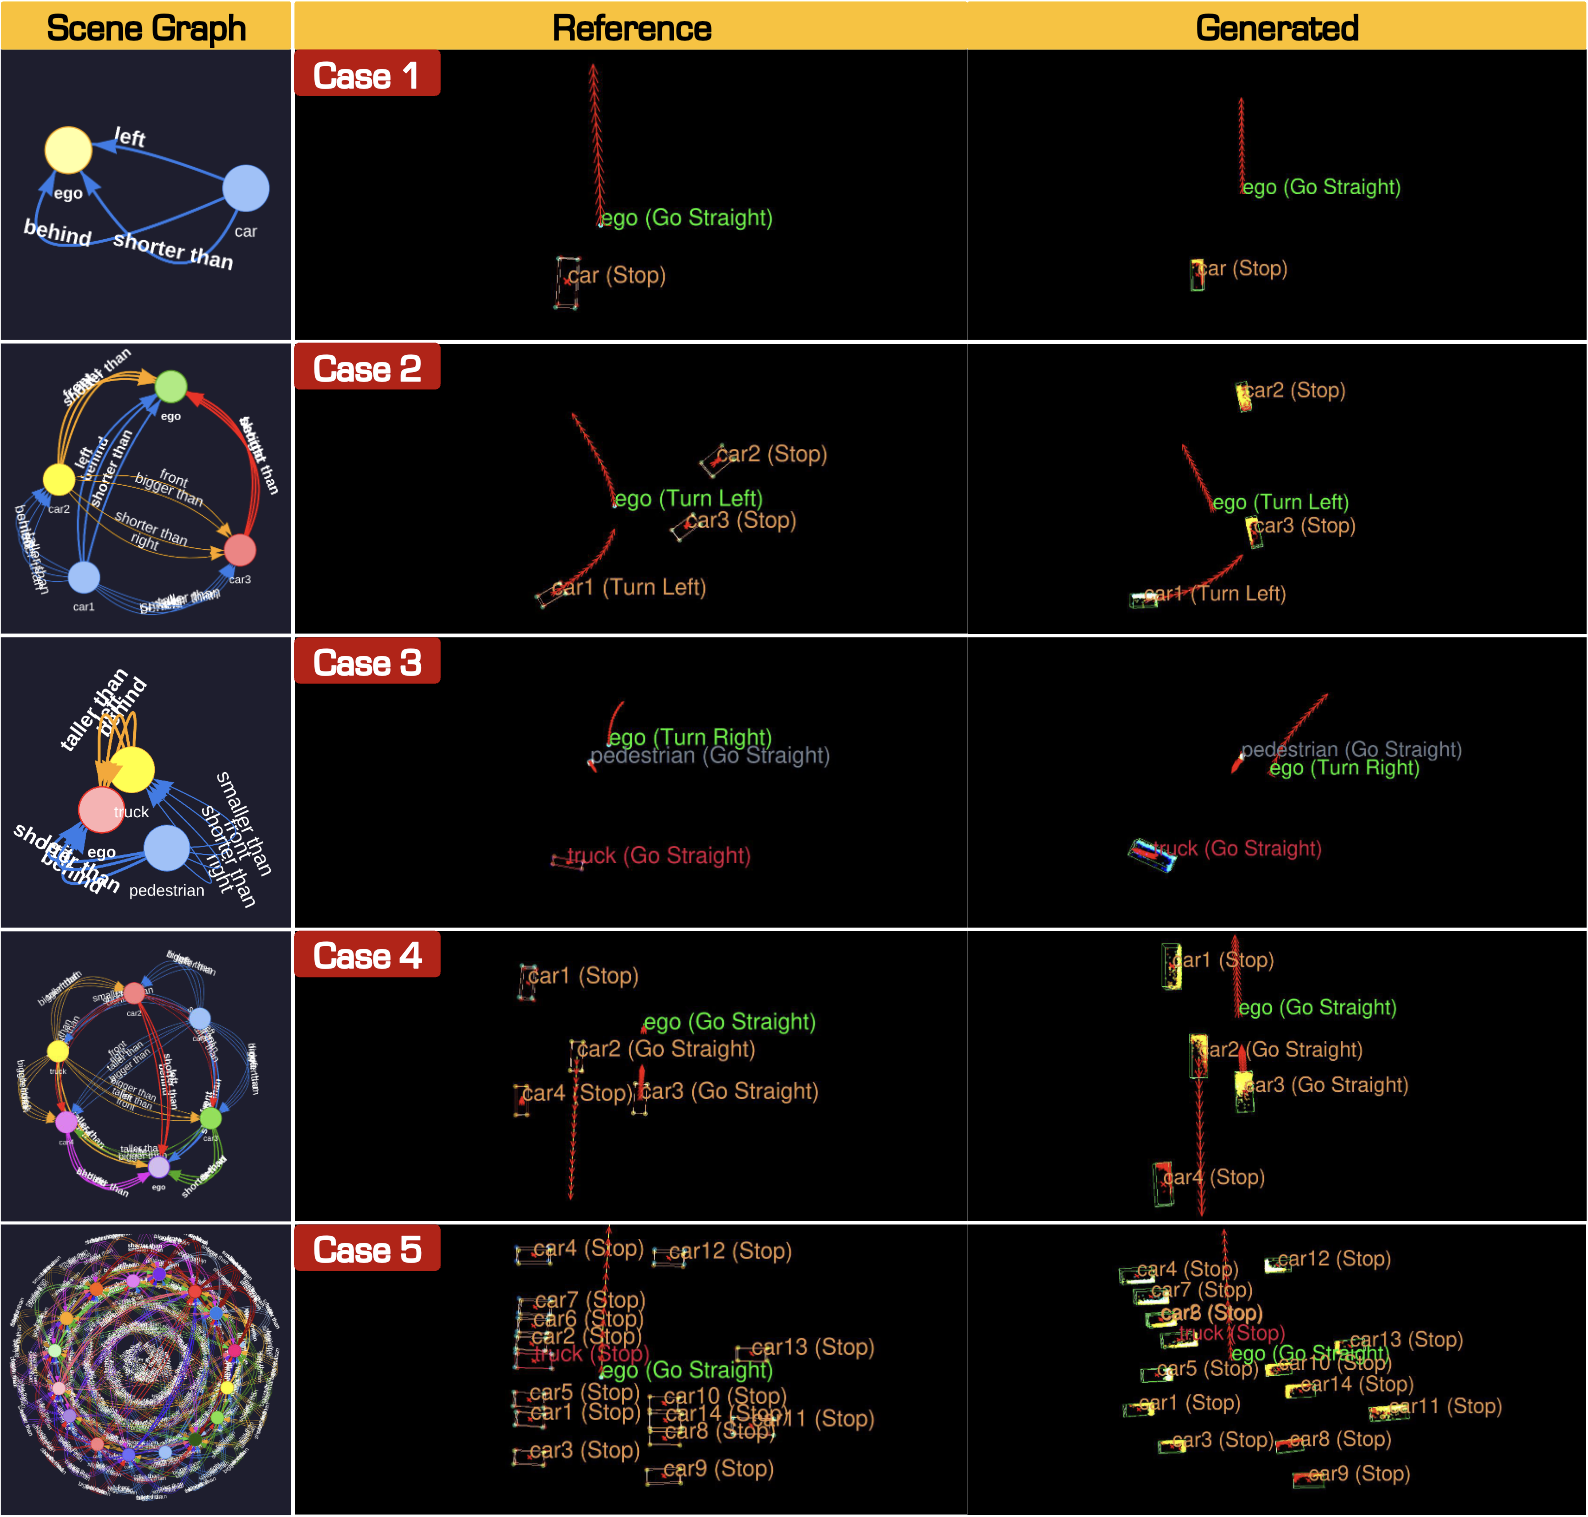
4D Layout Generation
Single-Frame Generation
:snake: Model Zoo
To be updated.
:memo: TODO List
- [x] Initial release. 🚀
- [x] Release the training code.
- [x] Release the inference code.
- [x] Release the evaluation code.
- [ ] Refine the Readme.md
License
This work is under the <a rel="license" href="https://www.apache.org/licenses/LICENSE-2.0">Apache License Version 2.0</a>, while some specific implementations in this codebase might be under other licenses. Kindly refer to LICENSE.md for a more careful check, if you are using our code for commercial matters.
Acknowledgements
This work is developed based on the MMDetection3D codebase.
<img src="https://github.com/open-mmlab/mmdetection3d/blob/main/resources/mmdet3d-logo.png" width="31%"/><br>
MMDetection3D is an open-source toolbox based on PyTorch, towards the next-generation platform for general 3D perception. It is a part of the OpenMMLab project developed by MMLab.
Part of the benchmarked models are from the OpenPCDet and 3DTrans projects.
Related Projects
| :sunglasses: Awesome | Projects |
|---|---|
| <img width="95px" src="https://github.com/ldkong1205/ldkong1205/blob/master/Images/worldbench_survey.webp"> | 3D and 4D World Modeling: A Survey<br>[GitHub Repo] - [Project Page] - [Paper] |
| <img width="95px" src="https://github.com/ldkong1205/ldkong1205/blob/master/Images/worldlens.png"> | WorldLens: Full-Spectrum Evaluations of Driving World Models in Real World<br>[GitHub Repo] - [Project Page] - [Paper] |
| <img width="95px" src="https://github.com/ldkong1205/ldkong1205/blob/master/Images/3eed.png"> | 3EED: Ground Everything Everywhere in 3D<br>[GitHub Repo] - [Project Page] - [Paper] |
| <img width="95px" src="https://github.com/ldkong1205/ldkong1205/blob/master/Images/drivebench.png"> | Are VLMs Ready for Autonomous Driving? A Study from Reliability, Data & Metric Perspectives<br>[GitHub Repo] - [Project Page] - [Paper] |
| <img width="95px" src="https://github.com/ldkong1205/ldkong1205/blob/master/Images/pi3det.png"> | Perspective-Invariant 3D Object Detection<br>[GitHub Repo] - [Project Page] - [Paper] |
| <img width="95px" src="https://github.com/ldkong1205/ldkong1205/blob/master/Images/dynamiccity.webp"> | DynamicCity: Large-Scale 4D Occupancy Generation from Dynamic Scenes<br>[GitHub Repo] - [Project Page] - [Paper] |