

Repository
RL2-VLA
RL²-VLA: Adaptive RL Latent Compositional Steering with Test-Time Scaling for Vision-Language-Action Models. Visit our project page: https://rl2-vla.github.io.
README
<h2 align="center">RL²-VLA: Adaptive RL Latent Compositional Steering with Test-Time Scaling for Vision-Language-Action Models</h2>
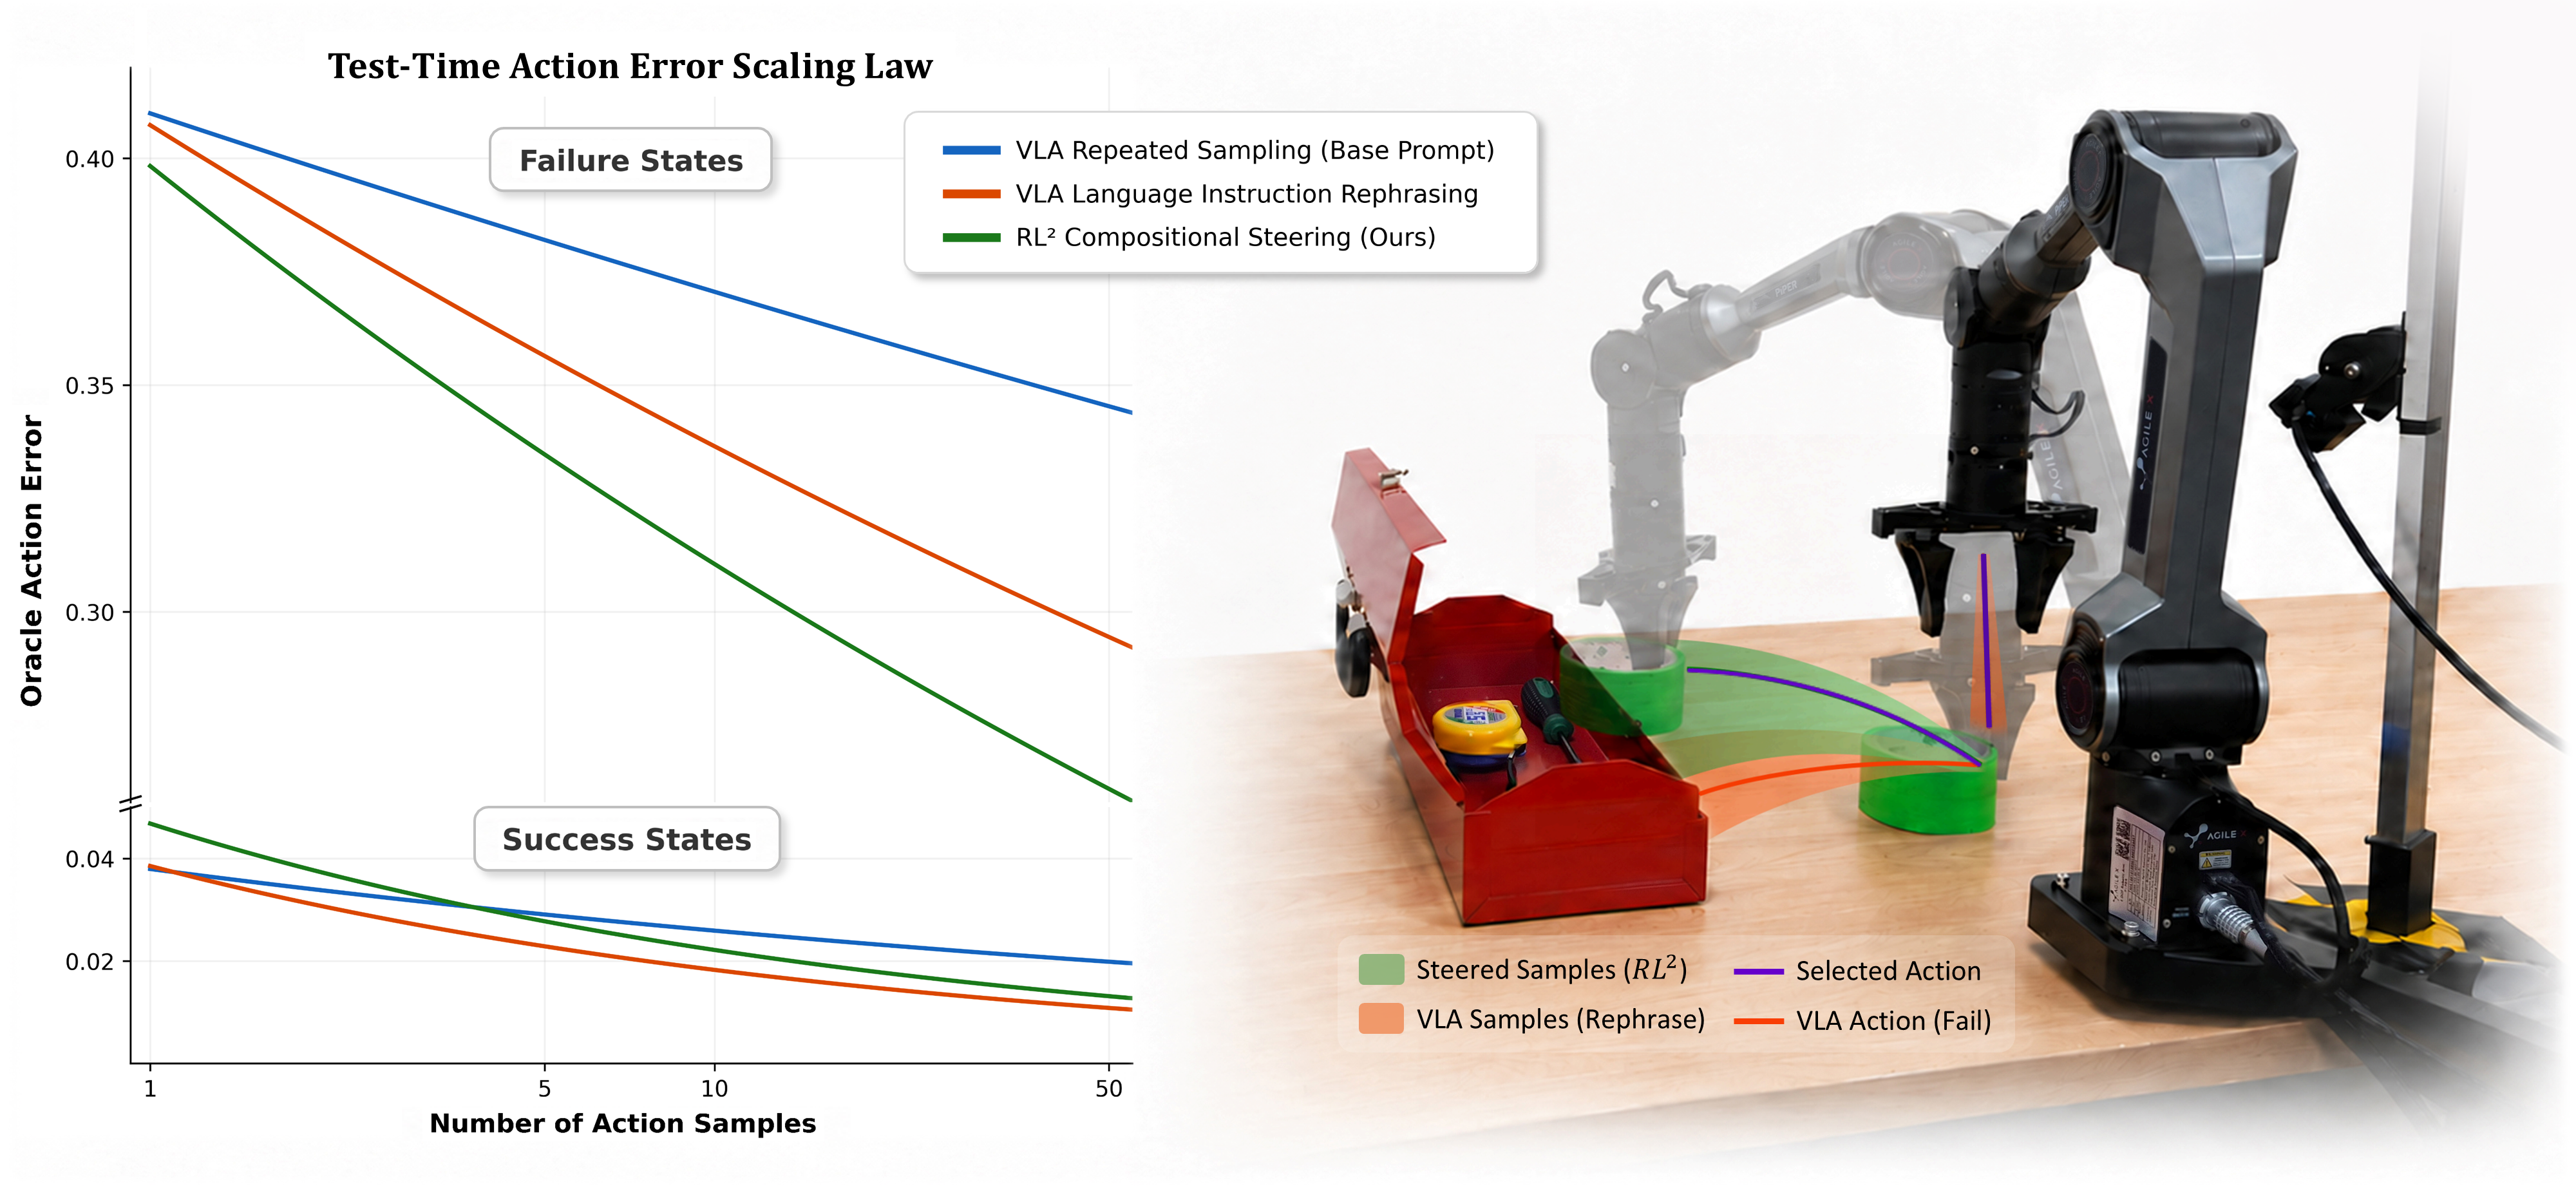 RL² improves VLA test-time scaling by adaptively applying RL compositional steering when the base VLA is likely to fail, particularly
in out-of-domain settings, without modifying the pretrained VLA.
📢 News / To-Dos
- [ ] Release RL²-VLA for PolaRiS simulation
- [ ] Release version optimized for inference speed
- [x] Initial release of RL²-VLA codebase for SIMPLER simulation
📚 Table of contents
<a id="setup"></a>
🛠️ Repository Setup
Code Setup
Clone the repository and submodules (i.e. SAFE, QAM) using the following:
git clone --recurse-submodules https://github.com/marmotlab/RL2-VLA.git
cd RL2-VLA/
Use the provided script to set up all dependencies. Please run from the root directory:
conda create -n rl2 python=3.10
conda activate rl2
bash RL2_CoVer_VLA/env_simpler_pi.sh
Requirements: Linux, Python 3.10, CUDA-capable GPU (e.g. H100, A6000, RTX5090).
Download Pretrained Checkpoints
1. SAFE Failure Detector
Provided directly in the SAFE submodule - no download needed.
However, we strongly encourage you to retrain the SAFE model with rollouts collected on your compute platform for better performance.
2. QAM RL Steering Policy
cd third_party/qam/exp/SAVED/rl2-vla-qam-bridge/
hf download rl2-vla/rl2-vla-qam-bridge rl2_vla_qam_bridge_500k.pkl flags.json --local-dir .
cd -
3. CoVer Bridge Verifier
cd bridge_verifier
hf download cover-vla/cover-vla-bridge cover_verifier_bridge.pt --local-dir .
cd ..
<a id="evaluation"></a>
🤖 SIMPLER Evaluation
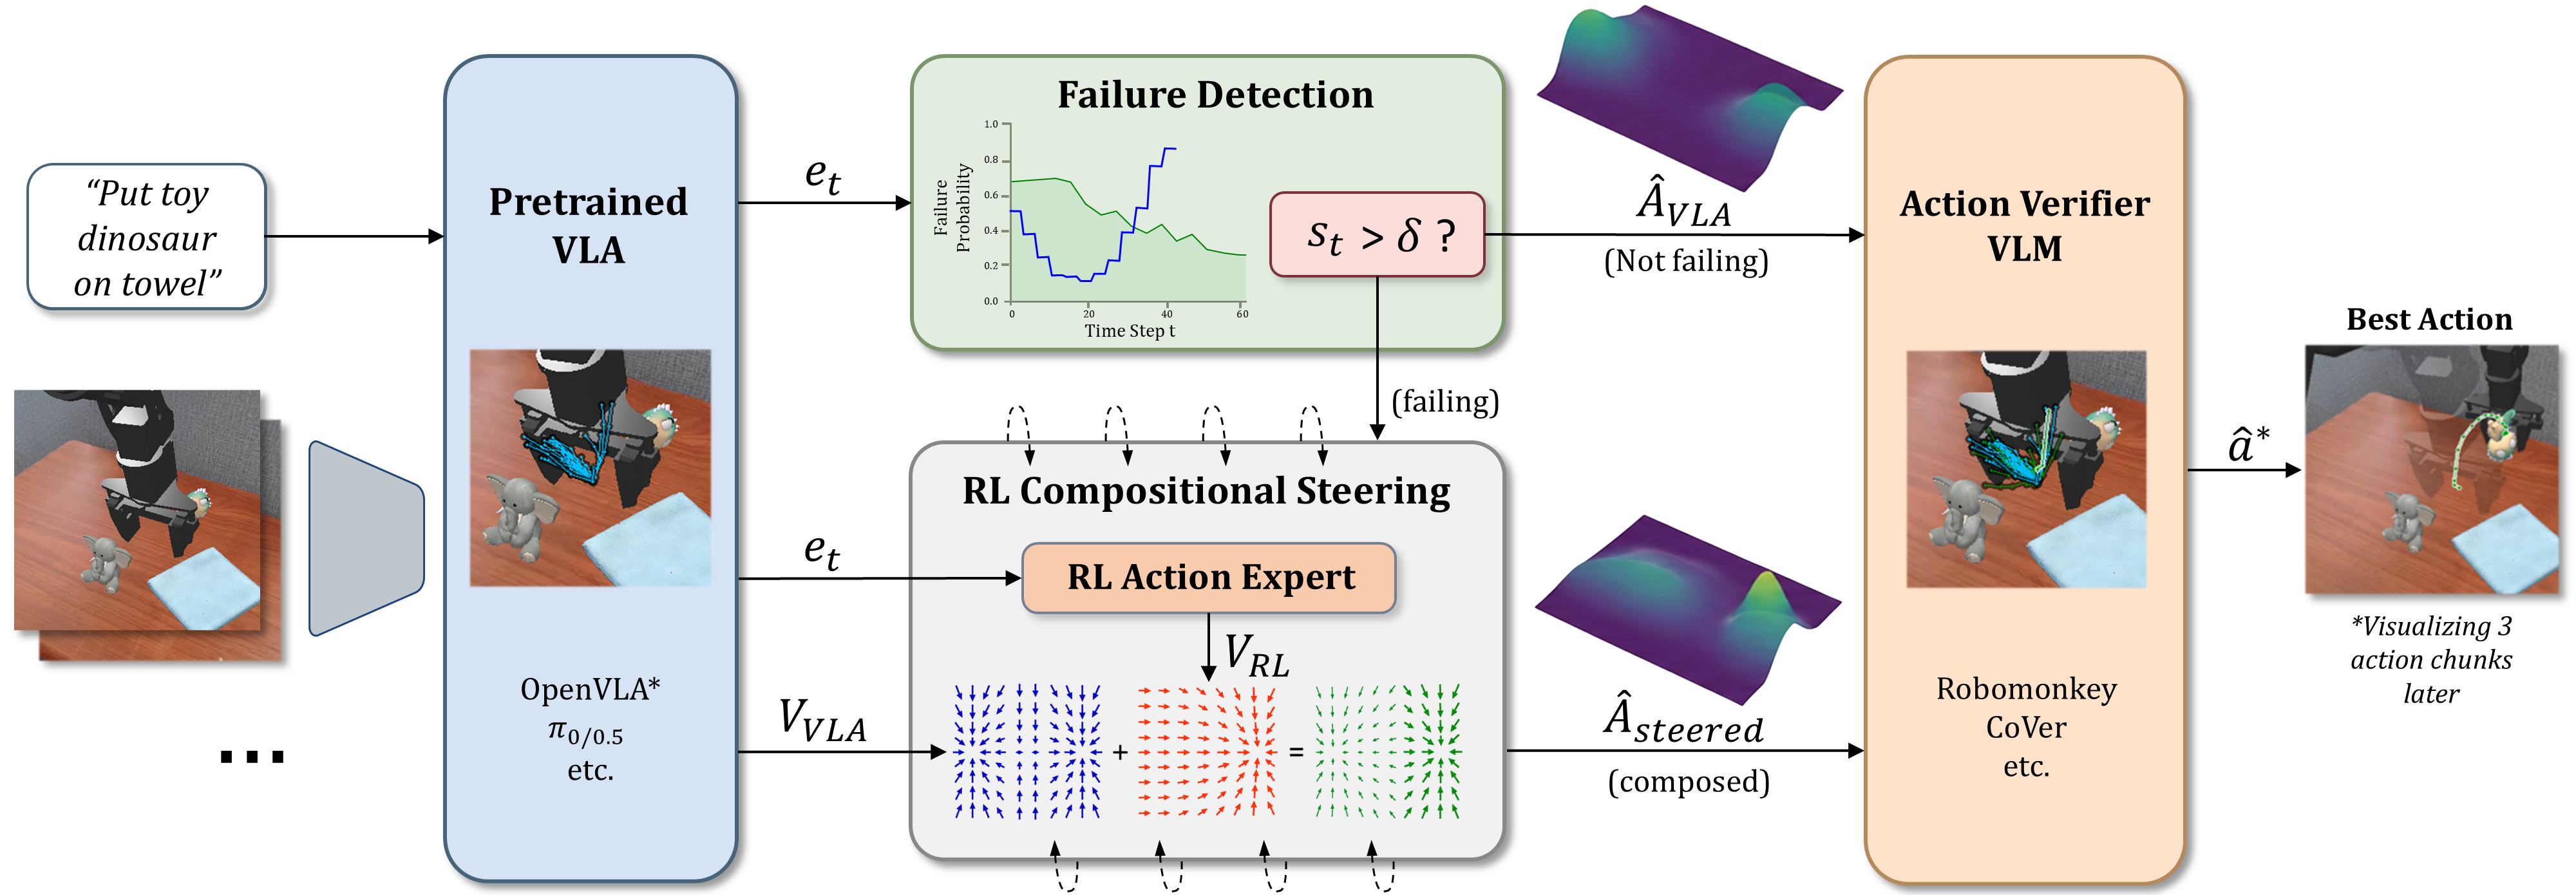
Evaluation Scripts
Run evaluation for in-domain and OOD task environments. Configure the essential parameters at the top of the bash scripts as needed.
conda activate rl2

# Adaptive RL2: Steering only during failure
bash RL2_CoVer_VLA/simpler/bashes/eval_rl2_compose_adaptive.sh

# Non-adaptive RL2: Steering at all times
bash RL2_CoVer_VLA/simpler/bashes/eval_rl2_compose_always.sh

# Rephrase: Language prompt rephrasing only
bash RL2_CoVer_VLA/simpler/bashes/eval_rephrase.sh
Summarize Results
After running inference, summarize success rates across seeds/tasks/methods into a table:
python RL2_CoVer_VLA/simpler/bashes/summarize_logs.py --logs_dir <PATH><a id="training"></a>
📊 Training
Train SAFE Failure Detector
You are strongly encouraged to retrain SAFE with rollouts collected on your compute platform.
-
Collect rollouts for SAFE training:
# rollout collection bash RL2_CoVer_VLA/simpler/bashes/collect_rollouts_for_safe_training.sh # restructure dataset python RL2_CoVer_VLA/simpler/bashes/restructure_rollouts_for_safe.py -
Train the detector using the guide in the SAFE README. Thereafter, update the evaluation bash scripts with the paths to the new SAFE checkpoint, CP bands, and alpha selection heuristic json files.
Train QAM RL Steering Policy
You may download the pretrained QAM steering policy from above. Alternatively, you may follow the steps below to train your own steering policy.
-
Download BridgeV2 dataset by following these instructions. You should download the
1.0.0version. -
Augment BridgeV2 Dataset with VLA latents:
python RL2_CoVer_VLA/simpler/extract_hidden_states_and_actions.py -
Train QAM using the guide in the QAM README. Thereafter, update the evaluation bash scripts with the path to the new QAM checkpoint.
Project Structure
RL2-VLA/
├── RL2_CoVer_VLA/
│   ├── env_simpler_pi.sh           # Setup script
│   ├── robot_utils.py              # Utilities
│   ├── simpler/
│   │   ├── run_simpler_eval_with_openpi.py   # Eval
│   │   ├── bashes/
│   │   │   ├── eval_rl2_compose_adaptive.sh
│   │   │   ├── eval_rl2_compose_always.sh
│   │   │   └── eval_rephrase.sh
│   │   └── ...
│   └── SimplerEnv/                 # Sim Env
├── bridge_verifier/                # CoVer Verifier
├── lerobot_custom/                 # LeRobot with PI0 policy
├── third_party/
│   ├── SAFE/                       # Failure detector
│   └── qam/                        # RL steering policy
├── INT-ACT/                        # OOD Envs
├── requirements.txt
└── README.md
<a id="troubleshooting"></a>
🔎 Troubleshooting
MuJoCo / OpenGL rendering: If you encounter display or rendering issues, ensure:
export MUJOCO_GL=osmesa
export PYOPENGL_PLATFORM=osmesa
Vulkan error: If you see No Vulkan extensions found for window surface creation, you may need to install Vulkan dependencies or use osmesa as above.
<a id="acknowledgements"></a>
✅ Acknowledgements
This repository is adapted from CoVer.
Our research is also based on RoboMonkey, SAFE, SimplerEnv, PolaRiS, and other related works.
We would like to thank the authors for their great work. Please refer to their papers for more details.
If you intend to use our work in your research, please cite the following publication:
@article{tan2026rl2,
  title={RL$^2$-VLA: Adaptive RL Latent Compositional Steering with Test-Time Scaling for Vision-Language-Action Models},
  author={Derek Ming Siang Tan and Shailesh Shailesh and Srikrishna Iyer and William Wei Jie Teo and Yuanliang Ju and Qiao Gu and Guillaume Sartoretti},
  year={2026},
  journal={arXiv preprint arXiv:2607.26991},
}