

Repository
Tac2Real
Tac2Real: Reliable and GPU Visuotactile Simulation for Online Reinforcement Learning and Zero-Shot Real-World Deployment
README
Overview
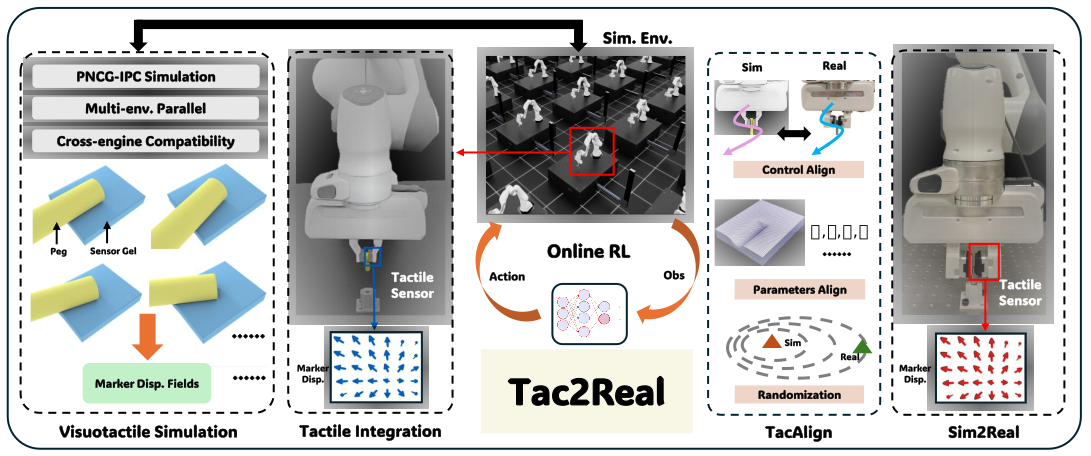
Tac2Real, a lightweight visuotactile simulation framework designed to enable efficient online RL training. Tac2Real
integrates the Preconditioned Nonlinear Conjugate Gradient Incremental Potential Contact
(PNCG-IPC) method with a multi-node, multi-GPU high-throughput parallel simulation architecture,
which can generate marker displacement fields at interactive rates. Meanwhile, we propose a
systematic approach, TacAlign, to narrow both structured and stochastic sources of domain gap,
ensuring a reliable zero-shot sim-to-real transfer. We further evaluate Tac2Real on the
contact-rich peg insertion task. The zero-shot transfer results achieve a high success rate in
the real-world scenario, verifying the effectiveness and robustness of our framework.
The code will be released after the paper is accepted.