

Repository
one-click-mujoco-azure
simup — my sim is up. One-click MuJoCo simulation environments on Azure ML.
- Azure
- AWS equivalent
- Subscription
- Subscription
- Resource Group
- Resource Group
- Command
- What it does
Specs
- AzureAWS equivalent
- SubscriptionSubscription
- Resource GroupResource Group
- CommandWhat it does
- simup preflightChecks Python version, Azure login, SSH keys, GPU quota -- everything you need before deploying
- simup deployProvisions a full VM (VNet, NSG, public IP, NIC, disk) and runs the MuJoCo setup script
- simup deploy --preset cpuSame as above but with a CPU-only VM -- no GPU quota required
- simup deploy --dry-runShows what would be created without actually creating anything
- simup listLists all simup -created VMs in your resource group
- simup status <name>Shows IP, size, region, and Jupyter URL for a specific VM
- simup ssh <name>Opens an SSH session to the VM (uses your configured key)
- simup jupyter <name>Prints the Jupyter Lab URL; add --open to launch it in your browser
- simup download <name> <remote> [local]Downloads files from the VM to your machine (no more Googling SCP syntax)
- simup destroy <name>Tears down the VM and all associated resources. This is the one that stops billing. Use it.
- simup configView or set defaults (subscription, resource group, location, SSH key)
- simup presetsShows all available VM size options with GPU type and cost
- PresetGPU
- small1x T4
- medium (default)1x T4
- large1x T4
- v1001x V100
- a1001x A100 80GB
- h1001x H100 NVL
- Use CaseRecommended
- Try MuJoCo for the first timecpu
- Interactive dev, debuggingcpu or small
- Video rendering, demosmedium or large
- Batched RL training (1000+ envs)a100 or h100
- ErrorFix
- requires a different Python: 3.9.x not in '>=3.10'Install Python 3.10+: brew install [email protected] (macOS) or apt install python3.12 (Ubuntu)
- OperationNotAllowed / exceeding quotaRequest GPU quota (see above ), or use --preset cpu
- SSH public key not foundGenerate: ssh-keygen -t rsa -b 4096 , or set path: simup config --ssh-key ~/.ssh/mykey
- InvalidResourceGroupLocationYour resource group is in a different region. Use --location matching your RG, or create a new RG
- OpenGL platform library has not been loadedSet MUJOCO_GL=egl (GPU) or MUJOCO_GL=osmesa (CPU) before running
- python: command not foundUse python3 instead of python
- VM running but MuJoCo not installed yetSetup takes 5-10 min after boot. Check: tail -f /var/log/simup-setup.log
README
simup: One-Click MuJoCo on Azure ML
simup ("my sim is up") is a simple CLI for deploying MuJoCo simulation environments on Azure ML. One command, and your sim is up.
Why This Exists
MuJoCo is a beautiful physics engine with an elegant API. But We hit surprising issues deploying it on Azure ML. We doumented the painful journey in our blog post Deploying MuJoCo on Azure ML and this simup is how we share a wrapper that helps people avoid these issues.
The goal is that simup deploy should be as easy as pip install for deploying MuJoCo on Azure ML.
What You Get from simup
A headless VM in the cloud with everything pre-installed:
- MuJoCo physics engine
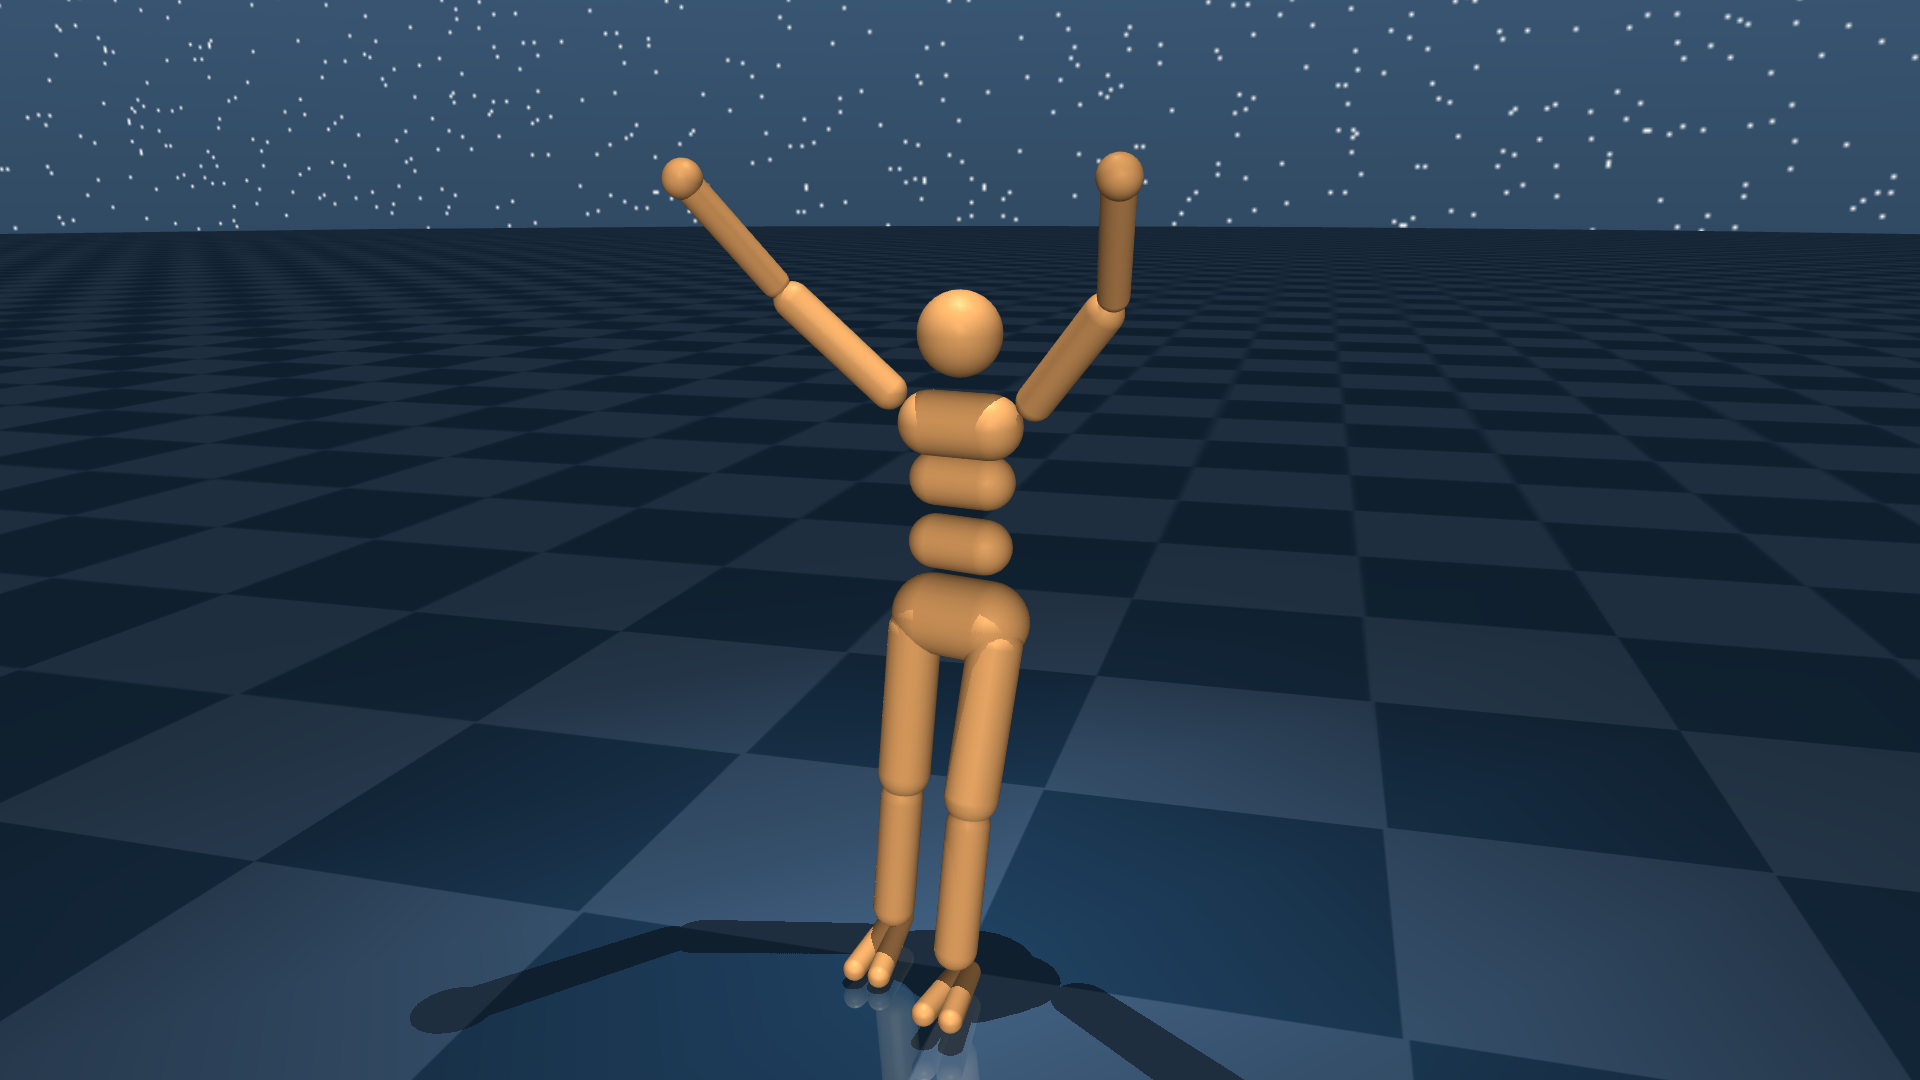
- dm_control humanoid demo (21 actuators, 17 bodies, 22 joints)
- Jupyter Lab in your browser for interactive simulation
- Example scripts for video rendering and benchmarking
Important: The VM has no monitor or GUI. (It's a cloud server, not a gaming PC.) You interact via:
- Jupyter Lab (browser) -- best for interactive work and inline video
- SSH -- run scripts, render video to MP4, download via
simup download
Prerequisites
Before you start, make sure you have:
- Python 3.10+ (check with
python3 --version) - Azure CLI installed (install guide)
- Azure account with an active subscription
- SSH key (
~/.ssh/id_rsaby default, or specify with--ssh-key)
That's the whole list. No GPU quota needed if you start with --preset cpu.
Finding your Subscription ID and Resource Group
simup needs two things from your Azure account: a Subscription ID and a Resource Group. If you're coming from AWS or GCP, here's the translation:
| Azure | AWS equivalent | GCP equivalent |
|---|---|---|
| Subscription | AWS Account | GCP Project |
| Resource Group | No direct equivalent (think of it as a folder that groups related resources -- VMs, networks, disks -- so you can manage and delete them together) | GCP Resource Group / Labels |
To find your Subscription ID:
- Go to portal.azure.com > Subscriptions > copy the Subscription ID
- Or run:
az account show --query id -o tsv
To find or create a Resource Group:
- Go to portal.azure.com > Resource groups
- Or create one:
az group create --name my-mujoco-rg --location eastus
Quick Start
Setup takes 5-10 minutes after the VM starts. Monitor progress:
simup ssh <name>
tail -f /var/log/simup-setup.log
# 1. Authenticate with Azure
az login
# 2. Clone and install
git clone https://github.com/Haptic-AI/one-click-mujoco-azure.git
cd one-click-mujoco-azure
python3 -m venv .venv && source .venv/bin/activate
pip install -e .
# 3. Configure (replace with your values)
simup config --subscription YOUR_SUBSCRIPTION_ID --resource-group YOUR_RG
simup config --ssh-key ~/.ssh/mykey # optional, defaults to ~/.ssh/id_rsa
# 4. Check everything is ready
simup preflight
# 5. Deploy
simup deploy --preset cpu # CPU (~$0.19/hr, no GPU quota needed)
simup deploy # medium T4 GPU (default, ~$0.75/hr, requires GPU quota)
simup deploy --dry-run # preview without creatingViewing Your Simulation
The VM is headless -- there is no display window. Here's how to see your work:
Option 1: Jupyter Lab (recommended)
simup jupyter <name> --openOpens Jupyter Lab in your browser. The demo notebook renders video inline -- no file downloads needed. You'll see the humanoid. It'll be standing there. It's beautiful.
Option 2: Render + Download
# SSH in and render a video
simup ssh <name>
python3 robot/simulate.py --video
# Video saved to /tmp/humanoid_sim.mp4 on the VM
exit

# Download it (this is why we built simup -- beats writing scp commands by hand)
simup download <name> /tmp/humanoid_sim.mp4 ./
open humanoid_sim.mp4
The simup CLI
| Command | What it does |
|---|---|
simup preflight |
Checks Python version, Azure login, SSH keys, GPU quota -- everything you need before deploying |
simup deploy |
Provisions a full VM (VNet, NSG, public IP, NIC, disk) and runs the MuJoCo setup script |
simup deploy --preset cpu |
Same as above but with a CPU-only VM -- no GPU quota required |
simup deploy --dry-run |
Shows what would be created without actually creating anything |
simup list |
Lists all simup-created VMs in your resource group |
simup status <name> |
Shows IP, size, region, and Jupyter URL for a specific VM |
simup ssh <name> |
Opens an SSH session to the VM (uses your configured key) |
simup jupyter <name> |
Prints the Jupyter Lab URL; add --open to launch it in your browser |
simup download <name> <remote> [local] |
Downloads files from the VM to your machine (no more Googling SCP syntax) |
simup destroy <name> |
Tears down the VM and all associated resources. This is the one that stops billing. Use it. |
simup config |
View or set defaults (subscription, resource group, location, SSH key) |
simup presets |
Shows all available VM size options with GPU type and cost |
VM Presets
| Preset | GPU | VM Size | Est. Cost |
|---|---|---|---|
cpu |
None (CPU only) | Standard_D4s_v3 | ~$0.19/hr |
small |
1x T4 | Standard_NC4as_T4_v3 | ~$0.53/hr |
medium (default) |
1x T4 | Standard_NC8as_T4_v3 | ~$0.75/hr |
large |
1x T4 | Standard_NC16as_T4_v3 | ~$1.20/hr |
v100 |
1x V100 | Standard_NC6s_v3 | ~$3.06/hr |
a100 |
1x A100 80GB | Standard_NC24ads_A100_v4 | ~$3.67/hr |
h100 |
1x H100 NVL | Standard_NC40ads_H100_v5 | ~$8.00/hr |
VMs bill while running. Run simup destroy <name> when done.
Most users should start with cpu. MuJoCo works fine without a GPU -- it's just slower for large-scale simulations. GPU presets require GPU quota which new Azure subscriptions don't have by default.
When to Use Which
| Use Case | Recommended | Why |
|---|---|---|
| Try MuJoCo for the first time | cpu |
No quota needed, cheapest |
| Interactive dev, debugging | cpu or small |
Good enough for most work |
| Video rendering, demos | medium or large |
More CPU/GPU helps with encoding |
| Batched RL training (1000+ envs) | a100 or h100 |
Need VRAM + MJX throughput |
Project Structure
one-click-mujoco-azure/
├── pyproject.toml              # Package config, "simup" CLI entry point
├── simup/                      # The CLI package (this is what `pip install -e .` installs)
│   ├── cli.py                  # All user-facing commands (Click + Rich)
│   ├── config.py               # Config loading (~/.simup/), presets, env vars
│   ├── azure_vm.py             # Azure SDK calls: create/get/list/delete VMs
│   └── startup_script.sh       # Cloud-init script that runs on first VM boot
├── robot/                      # Simulation code (deployed to the VM)
│   ├── simulate.py             # Headless humanoid sim + video rendering
│   └── humanoid_demo.ipynb     # Interactive Jupyter demo
├── examples/                   # Benchmarks and demos (deployed to the VM)
│   ├── humanoid_walk.py        # CPU vs GPU benchmark
│   └── batched_humanoid_mjx.py # 1024 parallel envs with JAX
├── tests/                      # 70 unit tests (run locally, no Azure needed)
│   ├── test_config.py          # Config loading, env vars, save/load
│   ├── test_azure_vm.py        # Name generation, SSH keys, wait logic
│   ├── test_cli.py             # All CLI commands via CliRunner
│   └── test_helpers.py         # Output parsing helpers
└── .github/workflows/ci.yml   # CI: lint, test, type-check on every PR
How the pieces connect: cli.py is the entry point -- it parses commands, loads config from config.py, and calls azure_vm.py to provision infrastructure. When a VM boots, startup_script.sh installs MuJoCo, JAX, and Jupyter, then deploys the files from robot/ and examples/.
Learning Path
New to robotics simulation? Here's a suggested path after your first deploy:
- Open the Jupyter notebook --
simup jupyter <name> --openand runhumanoid_demo.ipynb - Understand the model -- The notebook shows joint counts, actuators, and observation spaces
- Try other dm_control tasks -- Change
humanoid.standtohumanoid.walkorhumanoid.run - Run the benchmark --
python3 examples/humanoid_walk.pycompares CPU vs GPU performance - Scale up --
python3 examples/batched_humanoid_mjx.pyruns 1024 parallel environments via JAX - Bring your own robot -- Replace the model loading in
robot/simulate.pywith your own MJCF XML (convert from URDF if needed)
Resources:
Requesting GPU Quota
New Azure subscriptions have 0 GPU quota by default. You must request it:
- Go to Azure Portal > Subscriptions > your subscription
- Click Usage + quotas in the left sidebar
- Search for Standard NCASv3_T4 Family (cheapest GPU option)
- Click the edit icon and request a new limit of 8 (or more)
- Submit -- approval can be instant or take up to a few business days
While waiting, use simup deploy --preset cpu to get started on a CPU VM. Physics doesn't care what hardware it runs on.
Troubleshooting
| Error | Fix |
|---|---|
requires a different Python: 3.9.x not in '>=3.10' |
Install Python 3.10+: brew install [email protected] (macOS) or apt install python3.12 (Ubuntu) |
OperationNotAllowed / exceeding quota |
Request GPU quota (see above), or use --preset cpu |
SSH public key not found |
Generate: ssh-keygen -t rsa -b 4096, or set path: simup config --ssh-key ~/.ssh/mykey |
InvalidResourceGroupLocation |
Your resource group is in a different region. Use --location matching your RG, or create a new RG |
OpenGL platform library has not been loaded |
Set MUJOCO_GL=egl (GPU) or MUJOCO_GL=osmesa (CPU) before running |
python: command not found |
Use python3 instead of python |
| VM running but MuJoCo not installed yet | Setup takes 5-10 min after boot. Check: tail -f /var/log/simup-setup.log |
License
MIT
Built by Haptic AI. If this saved you a few hours of Azure debugging, we did our job.