

- Spec
- Value
- Height
- 1.2 m
- Weight
- 35 kg
- Degrees of Freedom
- 25 actuated + 2 passive
Specs
- SpecValue
- Height1.2 m
- Weight35 kg
- Degrees of Freedom25 actuated + 2 passive
- Legs6 DOF x 2 + toe x 2
- Arms5 DOF x 2 (shoulder pitch/roll/yaw, elbow, wrist yaw)
- Torso1 DOF waist yaw, 10 W 4 ohm speaker, 6 DOF IMU
- Head2 DOF neck (neck yaw, neck pitch), Quad microphone array, 2MP monocular camera
- CAN Bus5 @ 1Mbps + 1 @ 500kbps
- Onboard ComputeRaspberry Pi 5 (media + network) + Radxa CM5 (motion control)
- Structural Materials7075 aluminium, MJF PA12 nylon
- ActivityLoad
- Squat5 kg
- Bicep curl15 kg each arm
- Lateral raise18 kg each arm
- CategoryIncluded
- HardwareAll BOM components (unassembled), power supply & cabling, spare parts
- ComputeRPi edge board, motion control board, network board, power distribution board
- SensorsMonocular camera, IMUs, mic, speaker, motor joint states
- SafetyWireless E-Stop, safety guidelines
- DocsQuick start guide, manual, DIY build videos
- StatusItem
- ✅Mechanical CAD — 7 subassemblies
- ✅MuJoCo simulation model
- ✅Electrical wiring harness
- 🔜Electrical schematics & PCB files
- 🔜Asimov API
- 🔜Locomotion policy
- 🔜Mobile app
README
Asimov v1: Open-Source Humanoid Robot
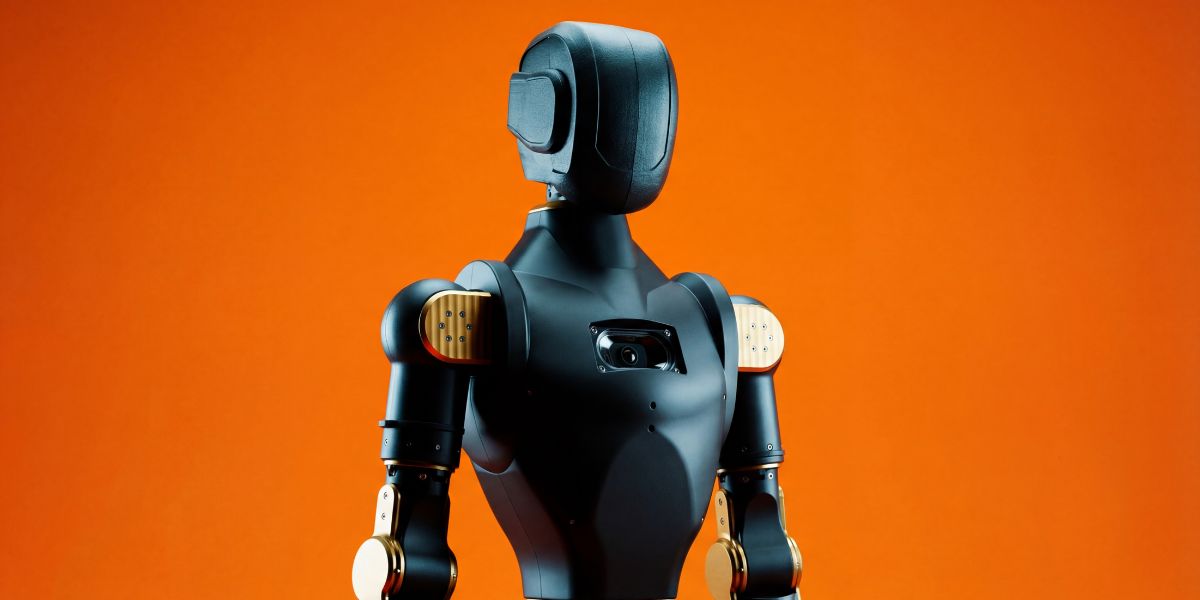
Asimov is an open-source humanoid robot that you can build, train and customize.
Website ·
Manual ·
DIY Kit ·
3D Model ·
Discord ·
X ·
Forum
Asimov v1 is a 1.2 m, 35 kg biped with 25 actuated degrees of freedom. This repository contains the mechanical CAD, electrical CAD, simulation model, and onboard software to build, simulate, and customize Asimov v1.
Specifications
| Spec | Value |
|---|---|
| Height | 1.2 m |
| Weight | 35 kg |
| Degrees of Freedom | 25 actuated + 2 passive |
| Legs | 6 DOF x 2 + toe x 2 |
| Arms | 5 DOF x 2 (shoulder pitch/roll/yaw, elbow, wrist yaw) |
| Torso | 1 DOF waist yaw, 10 W 4 ohm speaker, 6 DOF IMU |
| Head | 2 DOF neck (neck yaw, neck pitch), Quad microphone array, 2MP monocular camera |
| CAN Bus | 5 @ 1Mbps + 1 @ 500kbps |
| Onboard Compute | Raspberry Pi 5 (media + network) + Radxa CM5 (motion control) |
| Structural Materials | 7075 aluminium, MJF PA12 nylon |
| Activity | Load |
|---|---|
| Squat | 5 kg |
| Bicep curl | 15 kg each arm |
| Lateral raise | 18 kg each arm |
Build your own Asimov
[!TIP]
Option 1: DIY Kit: Everything you need to build Asimov v1, unassembled. $499 deposit to reserve. $15,000 target price. Ships summer 2026. Pre-order →
[!NOTE]
Option 2: Self-source: Pull the BOM and fabricate everything yourself. Assembly Manual →
DIY Kit
| Category | Included | Not Included |
|---|---|---|
| Hardware | All BOM components (unassembled), power supply & cabling, spare parts | Tools, hands |
| Compute | RPi edge board, motion control board, network board, power distribution board | 4G/5G modules |
| Sensors | Monocular camera, IMUs, mic, speaker, motor joint states | Lidar, 360 cam |
| Safety | Wireless E-Stop, safety guidelines | Battery |
| Docs | Quick start guide, manual, DIY build videos | — |
Pre-order the Asimov v1 DIY Kit →
Self-source
Pull the BOM, source the parts, fabricate what needs fabricating.
Roadmap
| Status | Item |
|---|---|
| ✅ | Mechanical CAD — 7 subassemblies |
| ✅ | MuJoCo simulation model |
| ✅ | Electrical wiring harness |
| 🔜 | Electrical schematics & PCB files |
| 🔜 | Asimov API |
| 🔜 | Locomotion policy |
| 🔜 | Mobile app |
Work with us
- Build questions?: Ask in the forum or open a GitHub Issue for bugs and contributions.
- Deploying Asimov?: Talk to us →
- Supply chain partner?: If you manufacture actuators, structural components, or electronics and want to be part of the Asimov supply chain, reach out.
[email protected]